
Hardware engineering / UAV flight stack
Drone Flight Controller And ESC PCB Design, From Concept To Second Revision
Flight-controller and ESC boards for a 7-inch drone, from requirements to manufactured, tested hardware.
The opportunity
A concept with no hardware
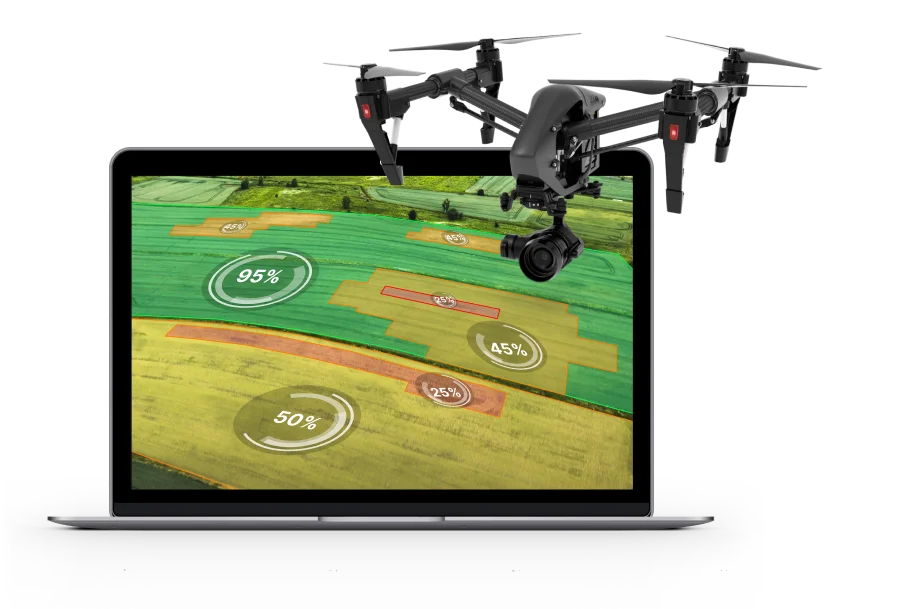
A drone company had a concept for a lightweight 7-inch drone and no requirements, schematics, boards or prototypes beyond the idea of a custom flight stack.
The solution
One matched flight stack
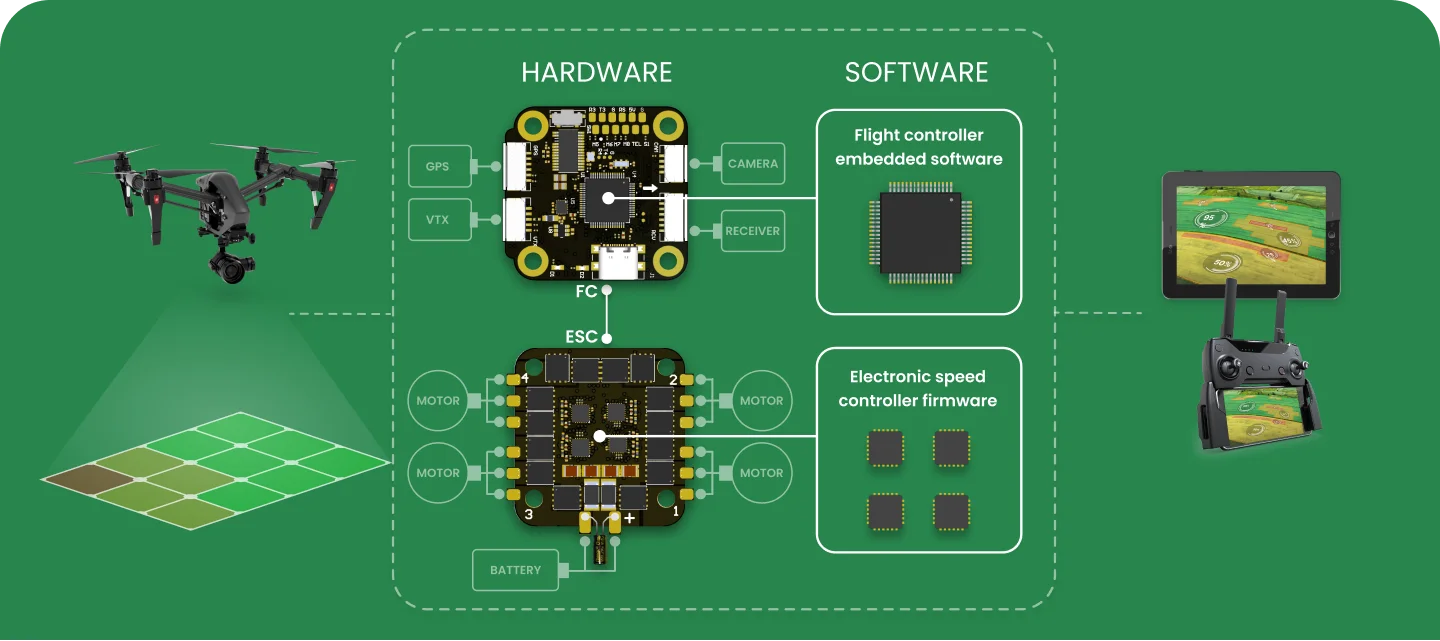
Indeema designed the flight-controller and ESC boards together, compatible with Betaflight and BLHeli, in a form a contract manufacturer can build.
- 01Requirements
- 02Board design
- 03Manufacturing files
- 04Bring-up
- 05Second revision
The impact
From concept to tested boards
- No requirements or schematicsRequirements and technical specification
- No boardsBoards built by an EMS vendor and tested
- No test evidenceBring-up and test reports
- First design onlyUpdated production files for revision two
Indeema delivered the electronics design and bring-up. The drone and its use are the client's.
Engineering judgement
Decisions that shaped the product
Prove the risky parts first
Prototype non-trivial components, such as the ESC MOSFETs under stress, before freezing the schematic.
Design for existing firmware
Make the boards compatible with Betaflight and BLHeli instead of writing flight and motor-control firmware from scratch.
Write the requirements down before drawing
Use a functional requirements document followed by a technical specification so that board-level choices trace back to stated product requirements.
Check before first power-on
Check for shorts, verify voltages and watch for overheating components before powering new boards, then load firmware to test function.
Treat bring-up as iterative
Plan for several rounds of testing and changes; feed results into updated production files for the next board revision.
Built with
Altium Designer · C/C++ · Assembly language · STM32F405 · Silicon Labs EFM8 Busy Bee · Betaflight · BLHeli
More case studies
All case studies ↗
Building equipment / Lift energy and usage monitoring
A lift energy and trip monitor, from meter interface to web portal
Smart home / Connected ventilation product
Electronics, firmware and app for a connected ventilation unit
Manufacturing / Indeema product: AI machinery condition monitoring
Turning machine vibration into condition-monitoring views
A comparable product problem?