
R&D / AI drone concept and proof of concept
Drone Proof Of Concept Development: A Follow-Me Drone With Wearable Alerts
Proof of concept for a companion drone that follows its user and sends alerts to a phone and wristbands.
The opportunity
A vision without an architecture
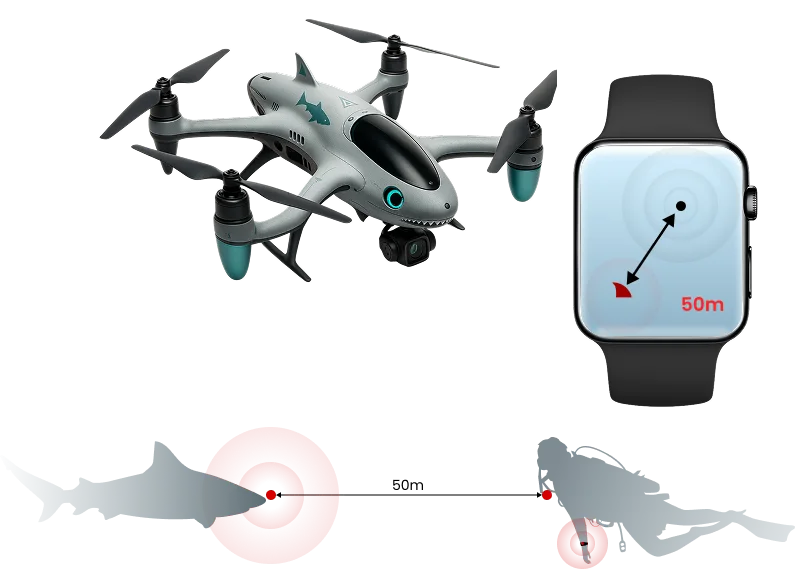
Hover Hero had a concept for a compact companion drone for open-water users. The founders had no architecture, selected hardware or software yet.
The solution
Show that it is feasible
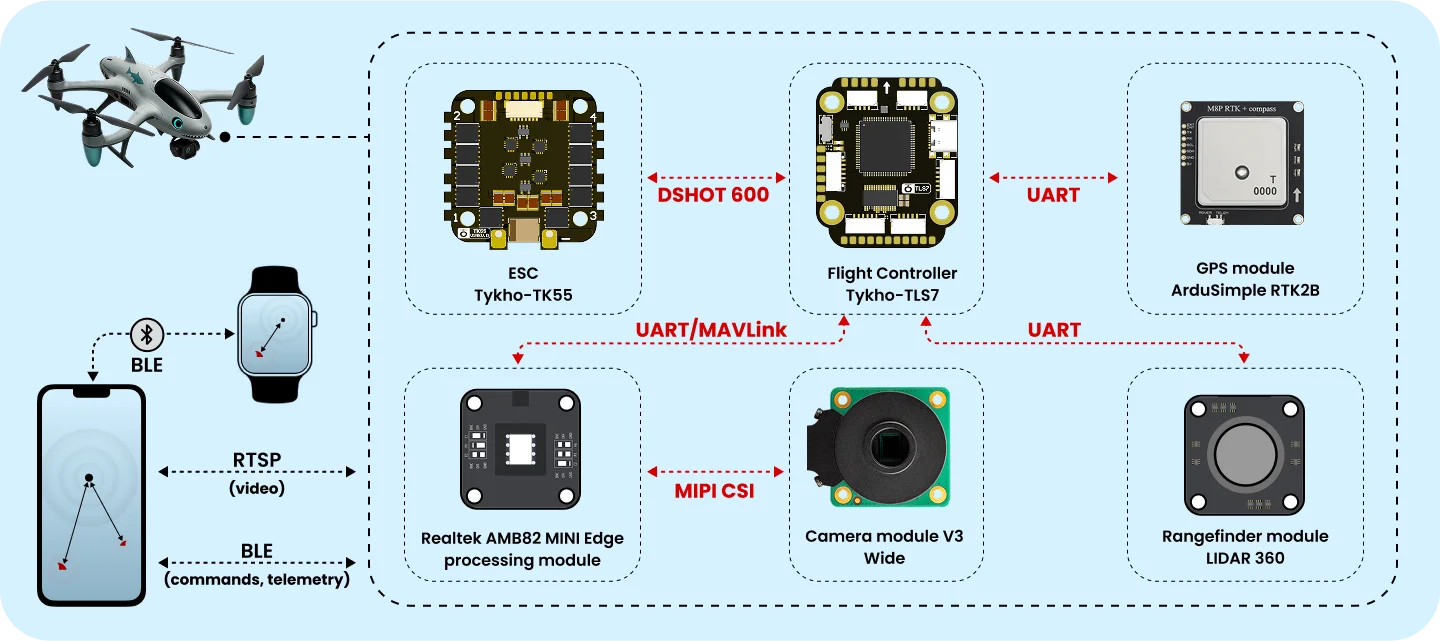
Indeema documented the architecture, tested follow-me on a real platform, trained a detection model and defined the alert flow to phone and wristbands.
- 01Architecture
- 02Drone platform
- 03Follow-me mode
- 04Detection model
- 05Alert flow
The impact
What the founders received
- High-level ideaDocumented system architecture
- Platform not chosenPlatform chosen through tests with the client
- No detection modelNeural network trained and evaluated on images
- No planEngineering documents and development plan
A proof of concept: alerts were tested with simulated targets on a floor, not with real sharks in open water.
Engineering judgement
Decisions that shaped the product
Reuse an existing hardware platform
Build on Indeema's existing drone hardware to speed up early validation.
Defer custom firmware
Use Betaflight or iNAV for flight control in the proof of concept, leaving room for custom firmware later.
Simulate the threat
Use a projector showing moving shapes as targets, so detection and alerts could be tested in a controlled setting before any open-water work.
Train the model in our own lab
Annotate drone-view imagery and train and evaluate the shark-detection network in Indeema's lab, measuring precision and recall at several input sizes.
Keep detection on the drone and lightweight
Choose a compact neural network, YOLO11n, suited to on-board processing so the alert path stays responsive.
Decide distance with field tests
Settle the follow-me configuration through real-world tests with the client rather than on paper.
Built with
Swift · C/C++ · Python · Betaflight / iNAV · STM32F405 · Silicon Labs EFM8BB21 · ESP32-C6 · YOLO11n
More case studies
All case studies ↗
Building equipment / Lift energy and usage monitoring
A lift energy and trip monitor, from meter interface to web portal
Smart home / Connected ventilation product
Electronics, firmware and app for a connected ventilation unit
Manufacturing / Indeema product: AI machinery condition monitoring
Turning machine vibration into condition-monitoring views
A comparable product problem?